SBG Systems
Ekinox Micro
Ekinox Micro is a high-performance GNSS aided Inertial Navigation System (INS) designed for use in a variety of land, marine, and airborne applications.
26 products
Ekinox Micro is a high-performance GNSS aided Inertial Navigation System (INS) designed for use in a variety of land, marine, and airborne applications.
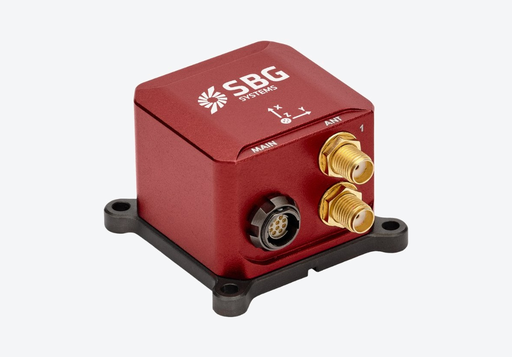
Miniature dual-antenna RTK INS: 0.05° roll/pitch with RTK, 0.2° heading and 1 cm RTK position; land and air version.
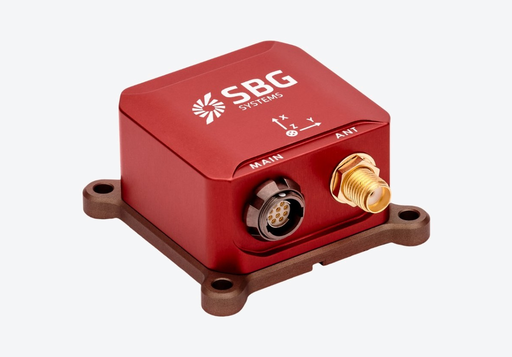
Miniature single-antenna RTK INS: 0.05° roll/pitch with RTK, 0.2° heading with vehicle dynamics and 1 cm RTK position; CAN version.
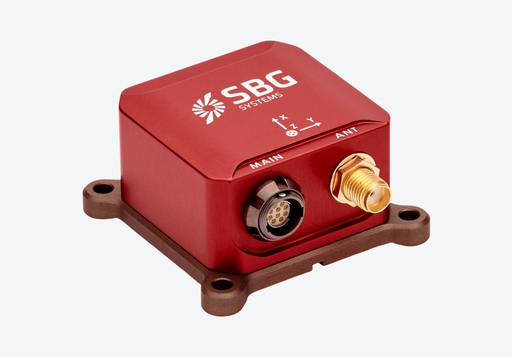
Miniature single-antenna RTK INS: 0.05° roll/pitch with RTK, 0.2° heading with vehicle dynamics and 1 cm RTK position; land and air version.
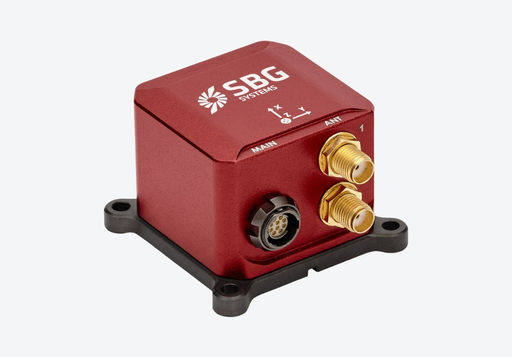
Miniature dual-antenna RTK INS: 0.05° roll/pitch with RTK, 0.2° heading and 1 cm RTK position; CAN version for land and air.
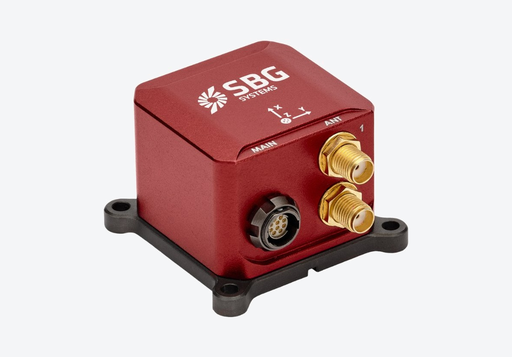
Miniature dual-antenna RTK INS: 0.05° roll/pitch with RTK, 0.2° heading and 1 cm RTK position; marine version with heave output.
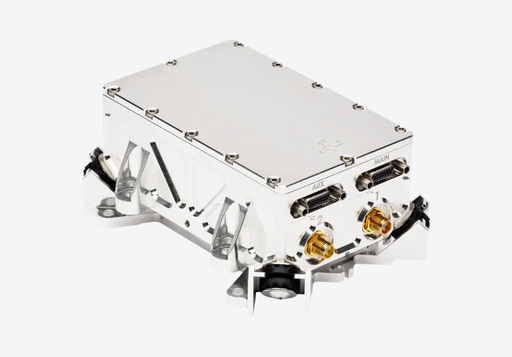
Tactical-grade GNSS/INS with a jamming- and spoofing-resilient receiver: 0.03° roll/pitch, 0.08° heading and 1 cm RTK; suspended mounting version.
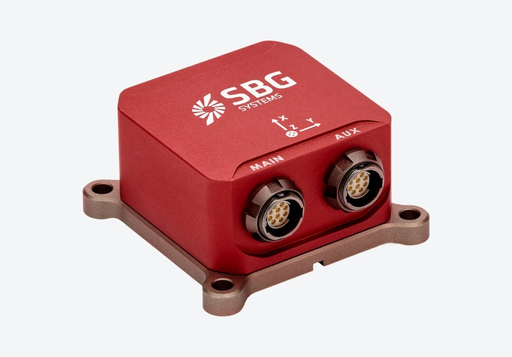
Miniature INS for an external GNSS receiver with built-in barometer: 0.1° roll/pitch, 0.2° heading, 0.03 m/s velocity; marine CAN version.
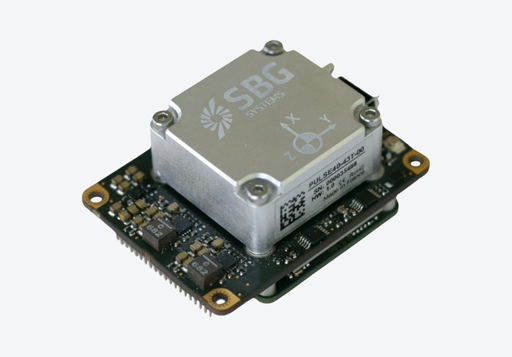
Compact GNSS-aided INS for UAV mapping: 0.03° roll/pitch, 0.1° heading (0.06° dual antenna) and multi-frequency quad-constellation GNSS with RTK and PPK.
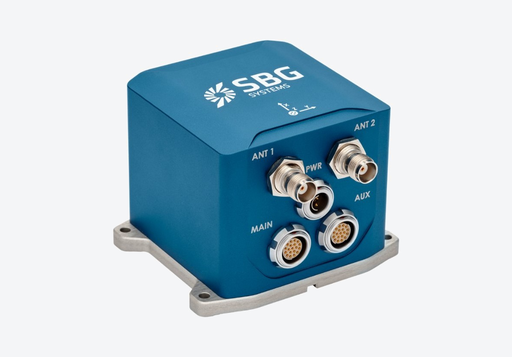
All-in-one INS with integrated RTK GNSS receiver: 0.02° roll/pitch, 0.03° heading and 1 cm RTK position, with Marinestar support, for land and air.
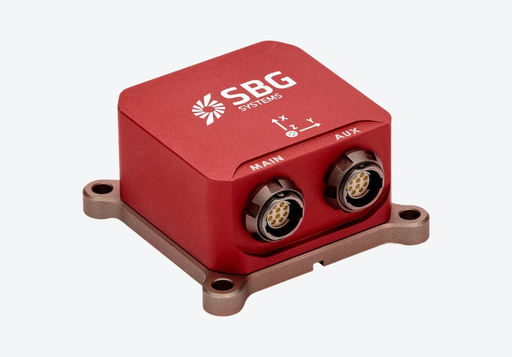
Miniature INS for an external GNSS receiver with built-in barometer: 0.1° roll/pitch, 0.2° heading, 0.03 m/s velocity; land and air version.
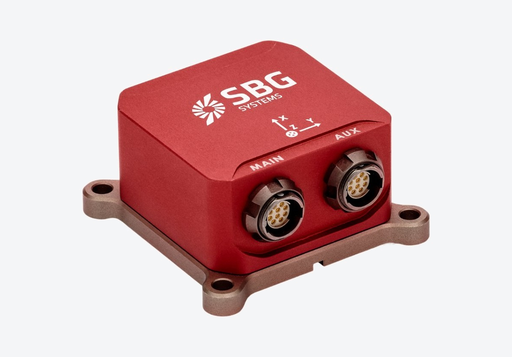
Miniature INS for an external GNSS receiver with built-in barometer: 0.1° roll/pitch, 0.2° heading, 0.03 m/s velocity; CAN version for land and air.
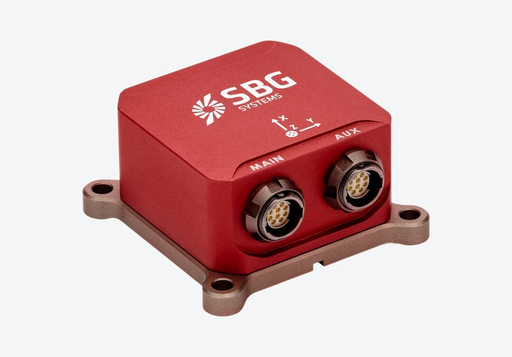
Miniature INS for an external GNSS receiver with built-in barometer: 0.1° roll/pitch, 0.2° heading, 0.03 m/s velocity; high-dynamics version.
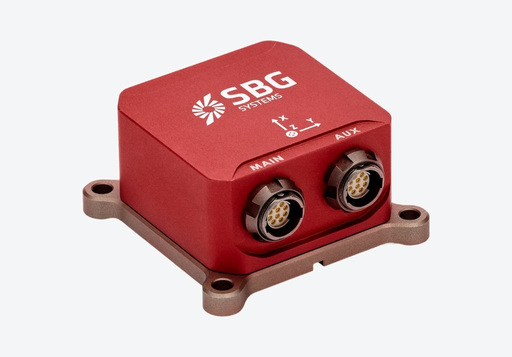
Miniature INS for an external GNSS receiver with built-in barometer: 0.1° roll/pitch, 0.2° heading, 0.03 m/s velocity; high-dynamics CAN version.
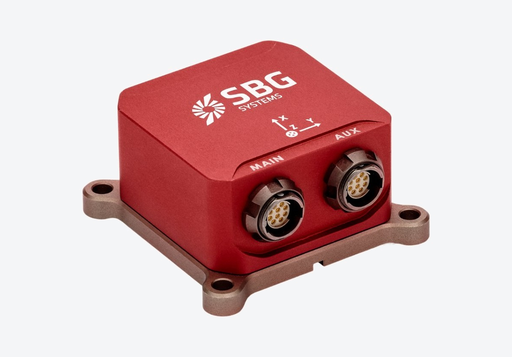
Miniature INS for an external GNSS receiver with built-in barometer: 0.1° roll/pitch, 0.2° heading, 0.03 m/s velocity; marine version with heave.
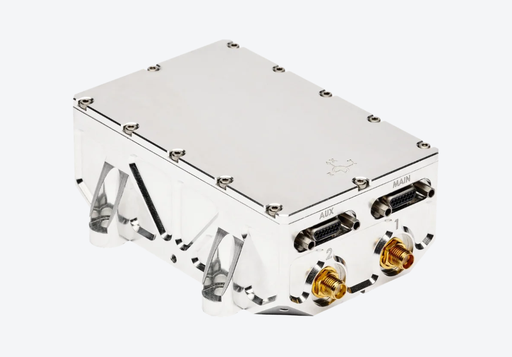
Tactical-grade GNSS/INS with a jamming- and spoofing-resilient receiver: 0.03° roll/pitch, 0.08° heading and 1 cm RTK; rigid mounting version.
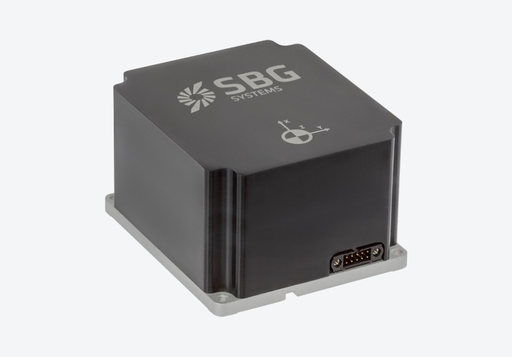
Compact INS/GNSS with the Pulse-80 IMU: 0.008° roll/pitch, 0.02° heading, 1 cm RTK and triple-frequency quad-constellation GNSS with anti-jamming.
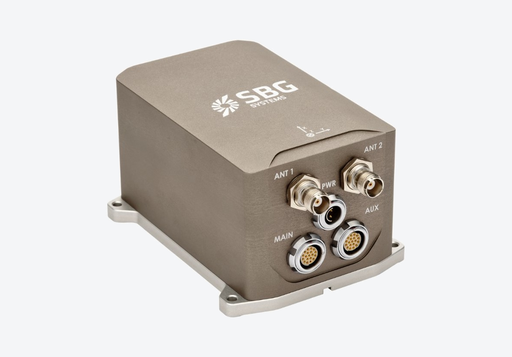
Dual-antenna INS/GNSS: 0.01° roll/pitch and 0.02° heading at 2 m baseline, 30 µg bias instability, compact and cost-effective for survey and mapping.
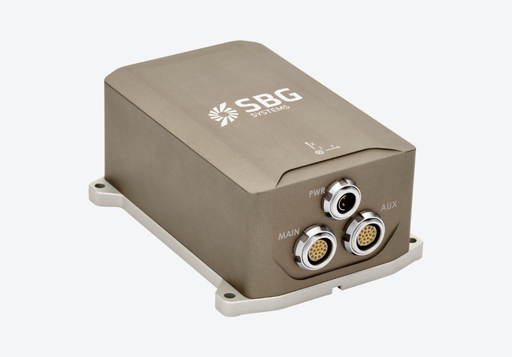
INS for an external GNSS receiver: 0.01° roll/pitch, 0.02° heading with a dual-antenna receiver, 200 Hz and 3 W, for survey, hydrography and mapping.
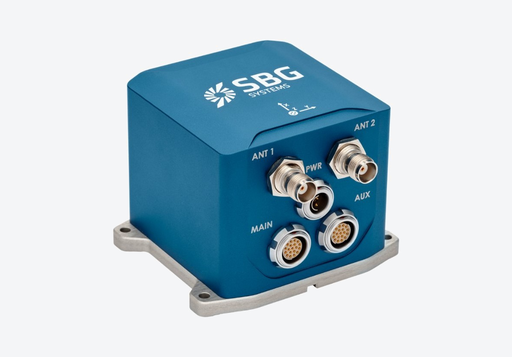
Dual-antenna RTK INS: 0.02° roll/pitch, 0.03° heading and 1 cm + 0.5 ppm RTK position in a 400 g unit, for survey, mapping and autonomous vehicles.
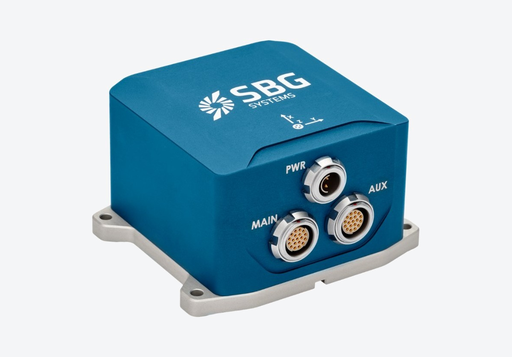
INS with external GNSS input: 0.02° roll/pitch, 0.03° heading and centimetre position with an RTK receiver, 400 g and 3 W.
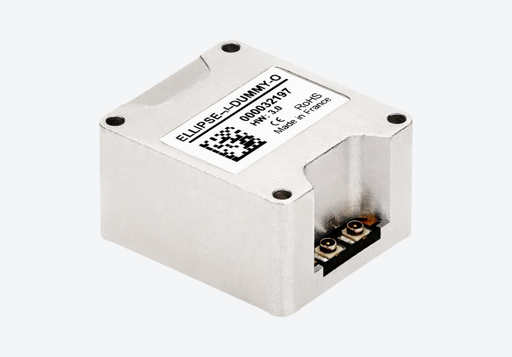
Board-level dual-antenna RTK INS (SMD): 0.05° roll/pitch with RTK, 0.2° heading and 1 cm RTK position, for integration into UAVs and robots.
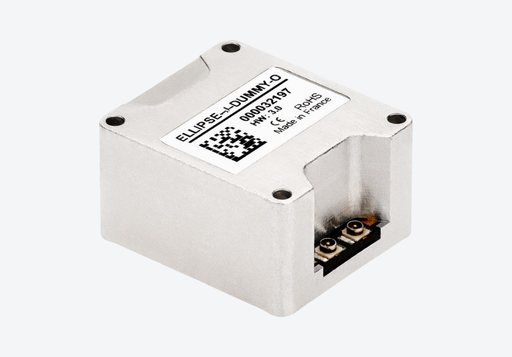
Board-level single-antenna RTK INS (SMD): 0.05° roll/pitch with RTK, 0.2° heading with dynamics and 1 cm RTK position, for UAVs and robots.
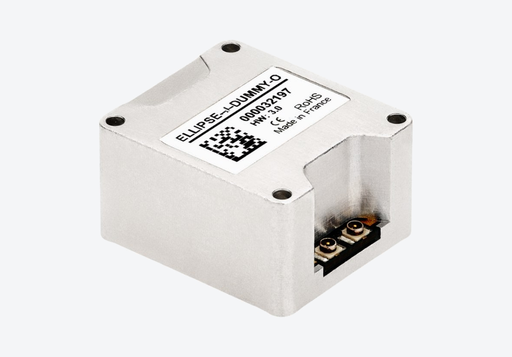
Board-level INS for an external GNSS receiver: 0.1° roll/pitch, 0.2° heading and 0.03 m/s velocity with a built-in barometer, for OEM integration.
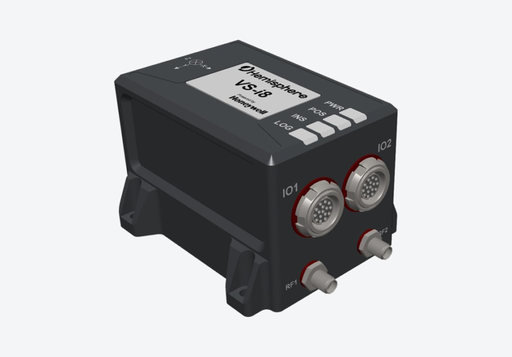
Vector INS combining multi-frequency GNSS with a Honeywell IMU: 0.03° heading, 0.015° pitch/roll and Atlas L-band, for marine and demanding navigation.
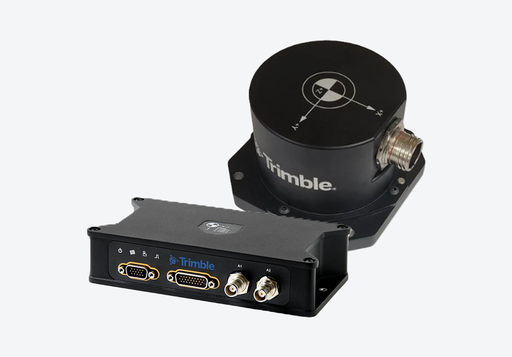
GNSS-inertial system for mobile mapping with an onboard and an external IMU: 0.03° roll/pitch and 0.09° heading with CenterPoint RTX corrections.