SBG Systems
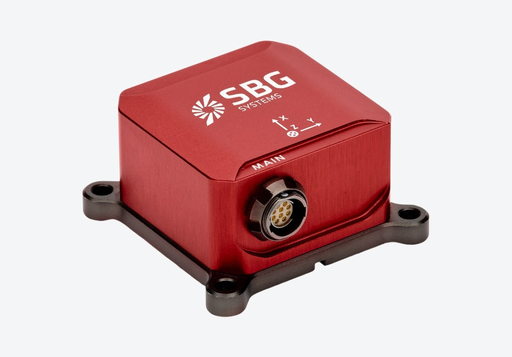
ELLIPSE-A - Land Air AHRS - CAN
Miniature 45 g AHRS with 0.1° roll/pitch, 0.8° magnetic heading and 200 Hz output, CAN version for land and air platforms.
12 products
Miniature 45 g AHRS with 0.1° roll/pitch, 0.8° magnetic heading and 200 Hz output, CAN version for land and air platforms.
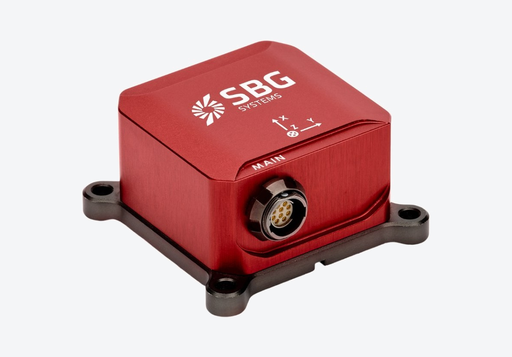
Miniature marine AHRS with 0.1° roll/pitch, 0.8° heading and 5 cm heave in a 45 g package, for boats, buoys and marine sensors.
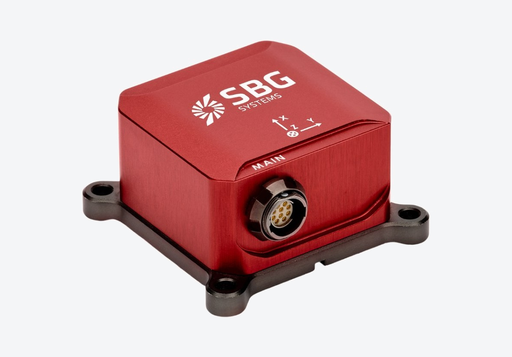
Miniature 45 g AHRS with 0.1° roll/pitch, 0.8° magnetic heading and 200 Hz output over RS-232, RS-422 or USB, for land and air platforms.
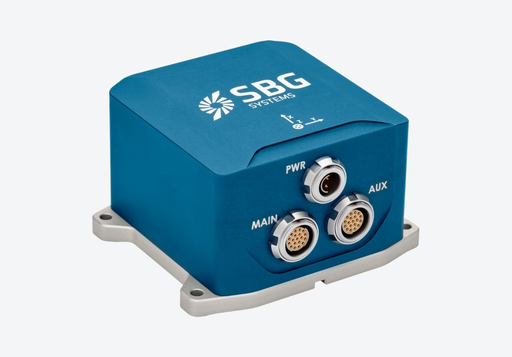
Marine INS and MRU for an external GNSS receiver: 0.02° roll/pitch, 0.03° heading and heave output at 200 Hz, for vessels and hydrography.
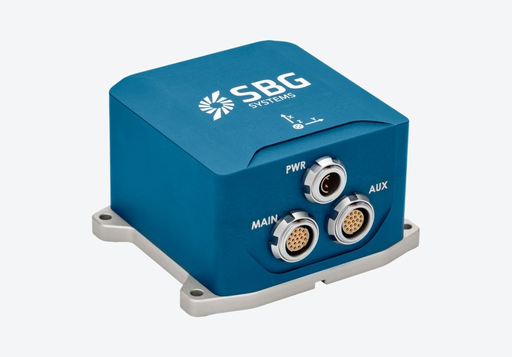
Marine MRU with 0.02° roll/pitch, 5 cm real-time heave and 200 Hz output, for vessel motion compensation and hydrographic survey.
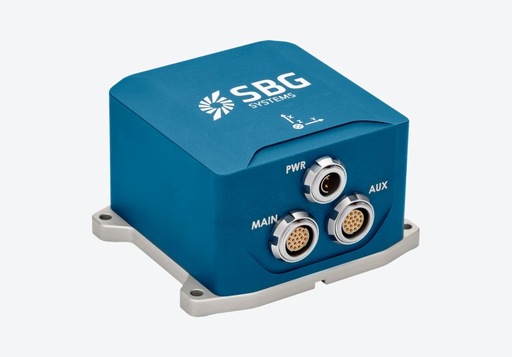
High-performance MEMS AHRS: 0.02° roll/pitch, 0.03° heading, 200 Hz output and 8 GB data logging, for land and air platforms.
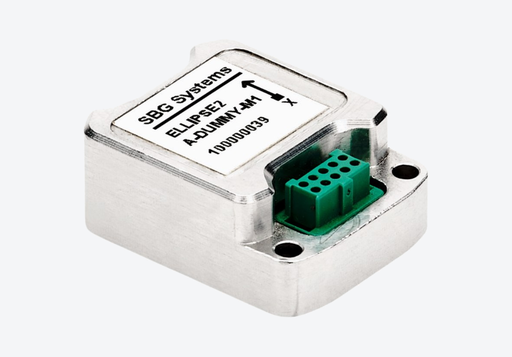
Sub-miniature MEMS AHRS: 0.1° roll/pitch, 0.8° heading, 7°/h gyro bias instability and ±450°/s range, for small platforms.
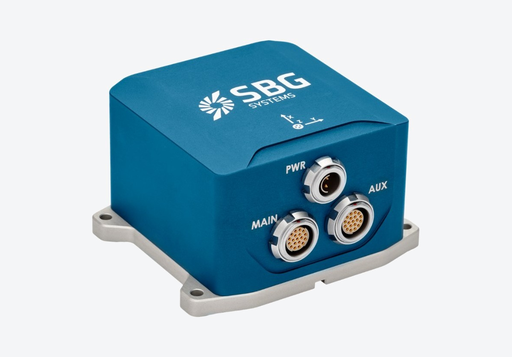
INS for an external GNSS receiver: 0.02° roll/pitch, 0.03° heading, 200 Hz output, 400 g and 3 W; land and air version.
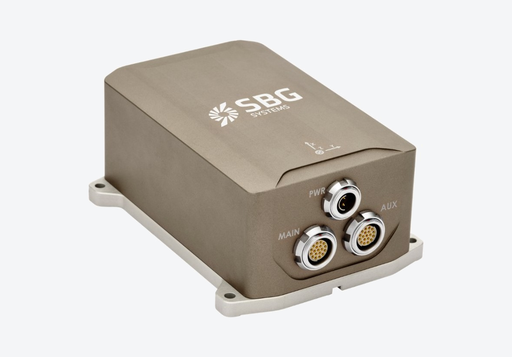
AHRS and MRU with 0.01° roll/pitch, 0.02° heading, 5 cm real-time heave and under 7 µg accelerometer bias, for motion compensation and survey.
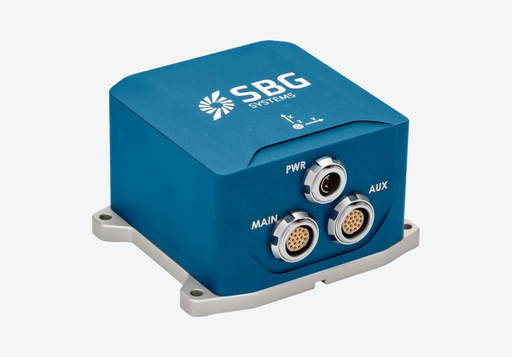
MEMS AHRS and MRU with 0.02° roll/pitch, 0.03° heading, 5 cm heave and under 10 µg accelerometer bias, for motion compensation and stabilisation.
8 g board-level AHRS with 0.1° roll/pitch, 0.8° magnetic heading and 200 Hz output, for integration into UAVs, robots and handheld devices.
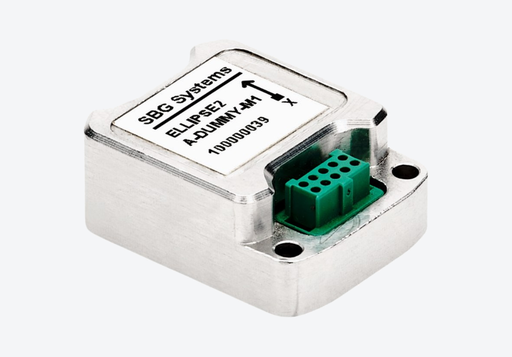
Sub-miniature AHRS for dynamic orientation: 0.1° roll/pitch and 0.8° heading, 7°/h gyro bias instability, ±16 g accelerometers, for UAVs and robots.