How to use fovlab
fovlab places a vehicle and its sensors in the same space and draws what their fields of view cover, so a layout can be checked before the parts are ordered. It runs in the browser at fov.leodrive.ai, it is free, and it needs no account. Nothing you enter leaves your machine unless you export it and send it to us.
The four views
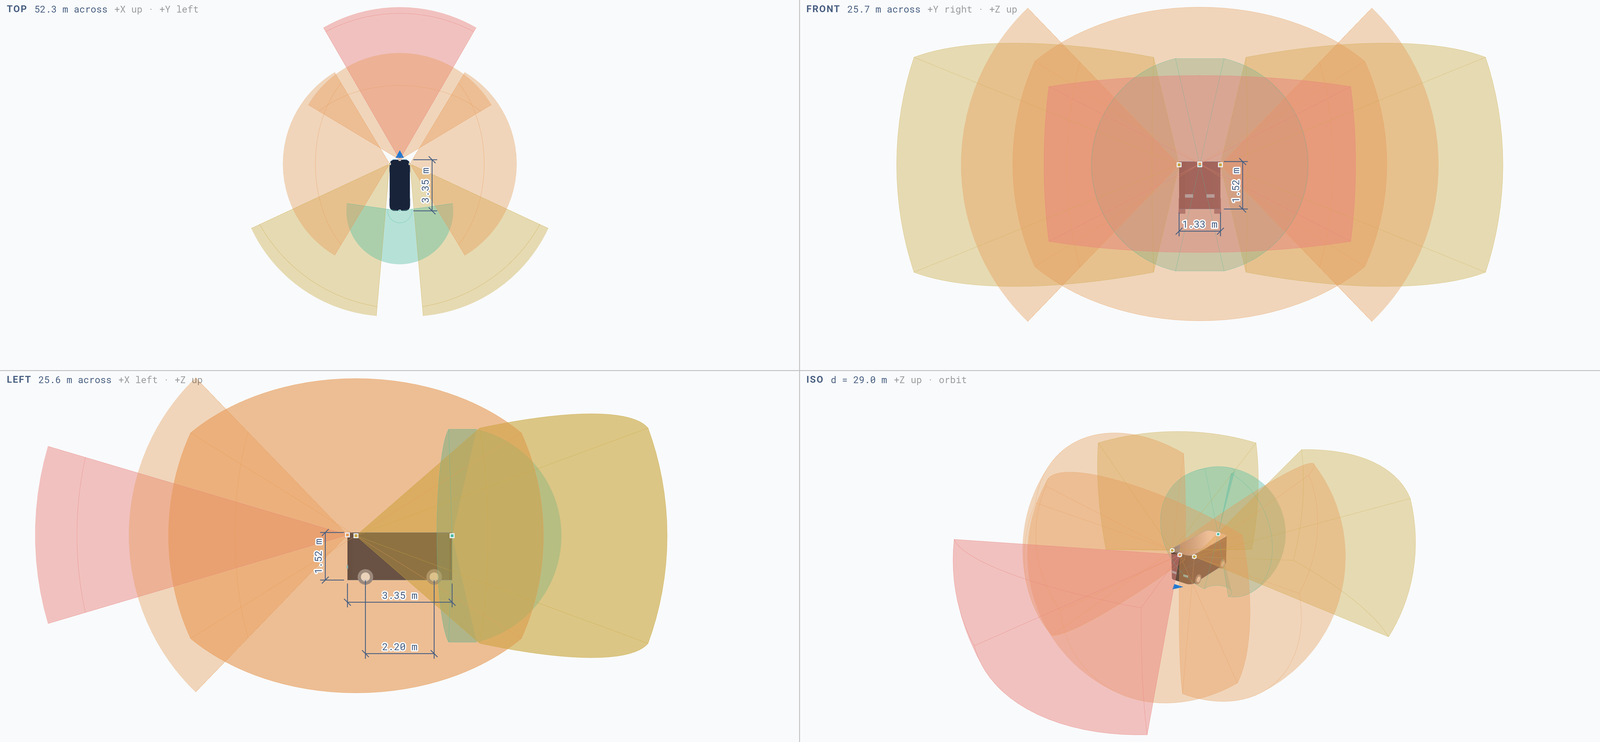
The screen opens on four synchronised viewports: TOP, FRONT, LEFT and an isometric ISO pane. Volumes that look continuous in a single 3D view separate when the same layout is seen down the vehicle axis, which is the reason for looking at all four at once.
- Link zoom ties the panes together so they stay at one scale.
- Fit all views frames the whole layout again after you have zoomed in.
- Double-click a pane to fill the screen with it; Esc, or the minimise button, brings the four back.
- Drag the divider between panes to resize them, and double-click it to reset.
The grid is fine to 25 m and heavy every 10 m, and it extends to 200 m, so distances can be read off the floor without measuring.
1. Set the vehicle
Start from a Preset — Car, Van or Bus — then set Length, Width, Height, Wheelbase, Wheel radius and Ground clearance.
Ground clearance and wheel radius matter more than they look. Together they set how high each sensor sits above the road plane, and the road plane is what a downward-tilted field of view intersects. A 100 mm change in clearance moves the blind ring in front of the bumper. Changing a preset replaces the body and keeps the sensors where they are.
2. Add sensors
Use Add to place a sensor, then give it a Sensor name, a Sensor type — Lidar, Camera or Radar — and a Sensor model. The model list carries real parts and arrangements such as Roof lidar 360°, Front lidar, Forward camera 60°, Surround camera 120° and Corner radar.
If the part you are evaluating is not in the list, Add sensor type and Add model let you define your own from its datasheet figures. A model you add is kept on that machine and appears in the list for every sensor afterwards.
3. Position and aim it
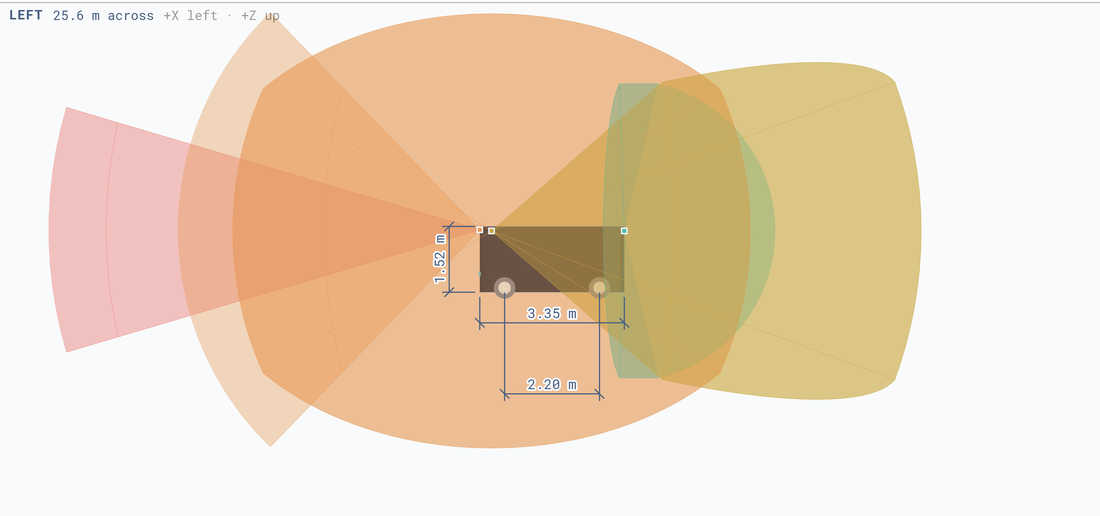
Under POSITION, place the sensor with X (fwd), Y (left) and Z (up), and aim it with Yaw, Pitch (+ up) and Roll (+ CW). MOUNTING SHORTCUTS drop a sensor onto a common mounting point without typing coordinates.
The axes follow ISO 8855, right-handed, with the origin on the ground at the centre of the footprint — +X forward, +Y left, +Z up. This is the same convention as ROS REP-103, so positions and rotations transfer into a URDF or an extrinsics file without sign changes. Because +Y is left, a symmetric pair of values means the sensor looks straight ahead.
Under FIELD OF VIEW, set HFOV, VFOV and Range. Far edge chooses how the far end is drawn: Fan, where every direction reaches the range, which is how a lidar behaves, or Flat. If you have edited figures away from the model and want them back, Restore returns every one to the model’s own value.
In the ISO pane you can work by hand: drag to move a sensor, hold Shift while dragging, or Alt / Option, to change what the drag does. Lock holds a sensor where it is so a stray drag cannot move it. Duplicate copies one across, and double-clicking a name renames it. If a sensor is placed inside the vehicle box, fovlab warns that the body will occlude it.
4. Read the metrics
Sensor metrics reports what the arrangement actually achieves, for the selected sensor and for the suite:
- Coverage — the ground this sensor covers.
- Ground reach — how far that covered ground reaches along the vehicle from the origin, with +X forward.
- Blind gap to body — the shortest distance from the vehicle to where coverage begins. This is the near-field ring in front of the bumper, and it is the number most layouts get wrong.
- Merged coverage — the union across every sensor.
- Field volume — the volume the field of view occupies.
- GROUND SAMPLE DISTANCE — for sensors whose model carries a resolution.
Display options
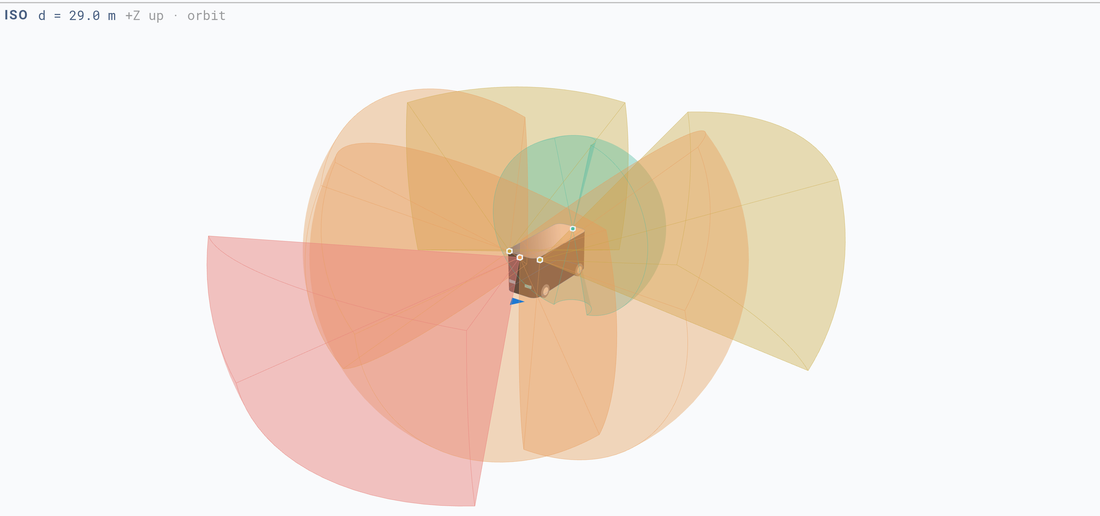
- Merge overlaps — overlaps stop compounding and the coverage draws as one shape. Every sensor keeps its own range; only the shading merges. Switch it off to see where volumes stack.
- FOV below ground — draws the part of a field of view that passes under the road. Off by default. Turning it on shows how much of a tilted sensor is pointed at tarmac.
- FOV opacity — for reading a layout with several volumes on top of one another.
- Grid, Grid (vertical) and Axes — reference geometry.
- Long ranges can be drawn compressed or at their true distance. Compressed keeps a 200 m radar on screen beside a 30 m camera; true distance is what to use when comparing reach.
What to look for
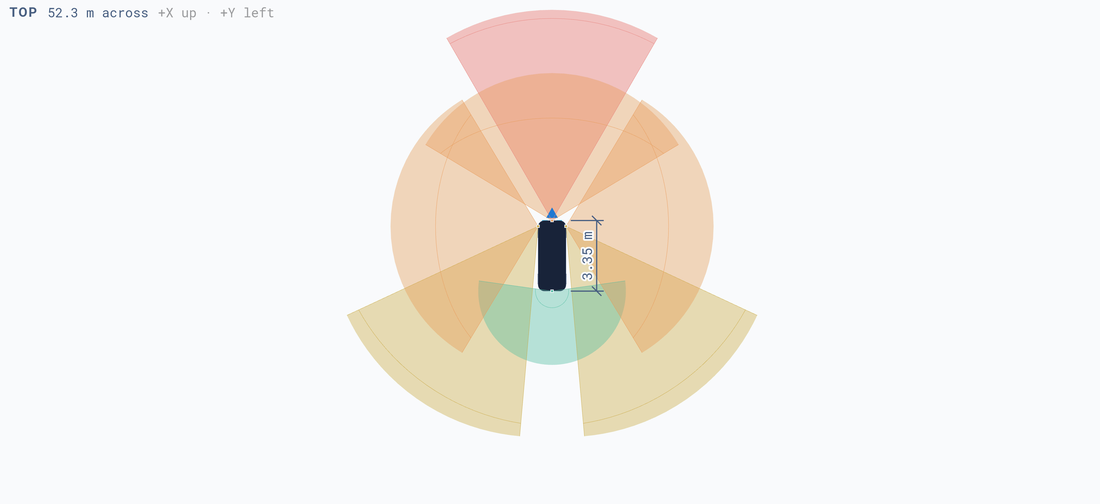
- The near-field ring. How wide it is, and what could be standing inside it. Read it from Blind gap to body.
- The mid-side gap behind the B-pillar. It closes with a corner sensor or a wider mount.
- Overlap. Toggle Merge overlaps to see whether sensors are duplicating cover instead of extending it.
- Wasted downward field. Turn on FOV below ground: a sensor tilted too far spends much of its field on road surface.
Keyboard and mouse
- Esc — back to the four views.
- Ctrl / Cmd + Z and Ctrl / Cmd + Y — undo and redo. Every destructive action, including a reset, can be undone.
- Delete / Backspace — remove the selected sensor.
- Double-click — a pane to maximise it, a sensor in ISO to focus it, a name to rename it.
- Scroll to zoom, middle-drag to pan.
Saving and sharing a layout
Export layout writes the vehicle, the sensors and any models they use to a file; Export vehicle writes the body alone, with no sensors on it. Import layout and Import vehicle read them back. Export drawing saves the viewport as a picture for a report or a review.
Send us an exported layout and we will quote the suite against it: contact Leo Drive.
What fovlab does not do
fovlab is not a sensor simulator. There is no ray tracing, no material response, no weather and no detection probability. It answers one question: given these mounting positions and these fields of view, what volume is covered. Range and detection performance come from the datasheet and from testing on the vehicle.
Background on why coverage is worth checking this early is in Where your sensors do not look.